Program
Last updated:

Moonshot Goal 3Realization of AI robots that autonomously learn, adapt to their environment, evolve in intelligence and act alongside human beings, by 2050.
Program Director (PD)KUNIYOSHI YasuoDirector, Next Generation Artificial Intelligence Research Center of The University of Tokyo / Professor, Graduate School of Information Science and Technology, The University of Tokyo
Outline
Considering Japan’s declining birthrate and aging population, it is important that robots can be used in all aspects of society - such as working in dangerous or understaffed sites, developing human frontiers, and supporting our everyday lives. For that purpose, robots must be able to learn and act on their own through the co-evolution of AI and robots. Our R&D aims to realize AI robots with advanced bodies and self-developed AI learning.
Message from PD
Our vision for 2050 is a world where general-purpose autonomous humanoid AI robots support every aspect of human society, dramatically enhancing human well-being. In such a society, robots will be ubiquitous as part of the infrastructure, and they must be capable of being flexibly deployed in response to emergencies and labor shortages.
To realize this vision, true general autonomy—defined as the ability to perform essentially any task that a human can—is indispensable. Achieving this requires capabilities such as understanding humans, learning in real time, ensuring safety in interactions with people, possessing human-level operational skills, and exhibiting a high degree of adaptability to diverse environments. To this end, we will establish a research portfolio that integrates three complementary frameworks—integrated research, specialized research, and elemental research—thereby covering a wide range of fields while achieving advanced system integration. Through innovative thinking that goes beyond conventional extensions, together with bold new ideas from early-career researchers and interdisciplinary collaboration, we aim to achieve this critical breakthrough.
R&D Projects
Selected in FY2026
Smart Robot AIREC that is Close to One Person for a Lifetime
- Project Manager
- OGATA Tetsuya
- Professor, Faculty of Science and Engineering, Waseda University

We aim to develop a versatile humanoid robot, AIREC (AI‑driven Robot for Embrace and Care), capable of supporting humans in real‑world applications such as welfare and caregiving, where severe labor shortages are imminent. AIREC will perform a wide range of highly complex physical tasks and engage in real‑world communication with humans through emotions generated from its own embodied system. Specifically, we will pursue innovation of high‑power humanoid robot bodies designed for integration with end‑to‑end AI, and realization of diverse physical tasks through deep predictive learning and robot foundation models, thereby advancing AI and robotics together. Through these efforts, we will implement physical support tasks that involve interaction with humans.
General-Purpose Autonomous Humanoids Growing through Multi-layered Instruction and Inheritance
- Project Manager
- KAWAHARAZUKA Kento
- Lecturer, Next Generation Artificial Intelligence Research Center, The University of Tokyo

We therefore aim to develop general-purpose autonomous humanoids that grow progressively through multi-layered instruction — hands-on guidance, learning by imitation, and verbal instruction — and through multi-layered inheritance of experience and skills from humans to robots, from robots to other robots, and from robots to humans. We will evaluate their adaptability, versatility, and ability to pass on what they have learned. Specifically, we pursue R&D on humanoids suited to instruction and inheritance, foundational systems that enable instruction and inheritance, task execution and real-world deployment based on instruction and inheritance, and next-generation community building. By 2050, we aim to realize humanoids that grow together with people and other robots by teaching and learning from one another, and that can take on all physical tasks that could reasonably be entrusted to part-time workers.
Integrated Research and Development of Humanoids Capable of Operating in Challenging Environments
- Project Manager
- HARADA Kensuke
- Professor, Graduate School of Engineering Science, The University of Osaka

This research aims to realize a humanoid robot capable of performing real physical work in unstructured and challenging environments such as construction sites. Its novelty lies in the integrated development of: (i) lightweight, high-power, and highly durable hardware; (ii) locomotion and whole-body motion planning that fuses model-based control with learning; (iii) manipulation skill acquisition that structures and extends the tacit knowledge of skilled workers; and (iv) human–humanoid and multi-robot collaborative intelligence enabled by multimodal AI. Using actual construction and manufacturing sites as demonstration fields, we will verify the system in a stepwise manner. We will establish the core technological foundation required for practical deployment at limited work sites by 2030 and for the realization of general-purpose autonomous humanoid AI robots by 2050. This project will make a significant contribution to resolving the increasingly severe labor shortage and to achieving safe and sustainable on-site operations.
Force Control as a Bridge between the Information World and the Physical World
- Project Manager
- SAKAINO Sho
- Associate Professor, Institute of Systems and Information Engineering, University of Tsukuba

This project aims to realize general-purpose robots that perform diverse non-routine tasks at human-level speed, addressing severe labor shortages. We fuse the recognition and decision-making capabilities of Vision-Language-Action (VLA) models with advanced force-control technologies based on bilateral control, so that robots adapt flexibly to on-site tasks through interactive feedback. We also develop bilateral control systems with a 15 Hz control bandwidth from the motor driver and gear levels, building a robot platform that is taught and adapts on site.
Robotics Platform for Emergent Intelligence Grounded in the Order of Embodied Interactions
- Project Manager
- NOZAKI Takahiro
- Associate Professor, Faculty of Science and Technology, Keio University

This project aims to develop robotic intelligence that understands object properties and possible actions from forces, motions, and energy exchanged through physical interaction. By integrating contact, friction, and deformation information across intelligence, embodiment, and simulation, we seek to build general-purpose autonomous robots that can safely complete tasks in unknown or disturbed environments and adapt flexibly to changes in people and surroundings.
Neuro-Robotics Pioneering Multimodal AI-Integrated Humanoid in Agriculture
- Project Manager
- HAYASHIBE Mitsuhiro
- Professor, Graduate School of Engineering, Tohoku University

To achieve AI-driven robotic automation in agriculture, key technical components—biomimetics, multimodal integration centered on visuo-tactile sensing, and meta-learning—play an indispensable role in realizing general-purpose embodied intelligence. We deploy "Artemy 2.0," created by adding tactile sensing capabilities to DENSO's agricultural robot Artemy, for early data collection. This drives the evolution into "Artemy 3.0," featuring enhanced embodied intelligence and wrist dexterity capable of executing harvesting, leaf pruning, and crop training. Furthermore, through "Agricultural Physical Foundation Model", we will realize multimodal integrated agricultural humanoids by combining rapid adaptation to unknown crops with physical adaptation driven by metacognition. By 2050, we aim to transform agriculture from "strenuous labor" into an "advanced intelligent industry" where humans and robots creatively coexist.
Creation of Embodied Intelligence through Self-Reinforcing Capability Expansion
- Project Manager
- MORIMOTO Jun
- Professor, Graduate School of Informatics, Kyoto University

We aim to establish a framework that enables humanoid robots to autonomously perceive their surroundings, explore appropriate actions, and learn through accumulated experience. Instead of relying on humans to explicitly teach individual movements, the robot will determine what to try next and progressively expand its behavioral capabilities through its own interaction with the environment. To achieve this, we will integrate a high-level mechanism for understanding the environment and selecting appropriate actions with a low-level mechanism for generating and executing whole-body movements according to the current situation. By tightly coupling these processes, we seek to build a foundation for humanoid robots that can adapt flexibly to diverse environments, continuously acquire new capabilities, and autonomously improve through experience.
Next-Generation Humanoid AI Robots through Whole-Body Tactile Intelligence
- Project Manager
- IIDA Fumiya
- Professor, Graduate School of Engineering, The University of Tokyo

This project aims to achieve a fundamental advancement in general-purpose autonomous humanoid AI robots by establishing core technologies centered on whole-body tactile sensing using electrical impedance tomography (EIT) and overcoming limitations in conventional robotic body structures. Next-generation EIT-based tactile sensors offering wide-area coverage, high spatial density, and high sensitivity will be integrated across the entire body of a humanoid AI robot using flexible functional materials. By processing vast amounts of tactile data in real time through attention mechanisms, the project will develop a new model of embodied intelligence that enables the robot to sense, act, understand, and adapt using its entire body.
Development of Dynamical Representation Learning for Cooperative Stable Motions and a Data‑Driven Motion Primitive Generation Framework
- Project Manager
- KAWAHARA Yoshinobu
- Professor, Graduate School of Information Science and Technology, The University of Osaka

We will develop technologies for generating cooperative motions that enable robots working with humans to continue operating safely despite changes in the environment and unexpected contact, and to recover from disturbances. We will integrate Koopman analysis, a mathematical approach to analyzing nonlinear dynamics, with dynamic movement primitives (DMPs), a conventional framework for stable motion generation, and establish a method for learning reusable motion representations from diverse data. This will enable robots to adapt rapidly to changing situations during task execution by combining motions and updating intermediate goals, without requiring large-scale retraining. We will also develop technologies for reducing model size while preserving stability, thereby enabling low-latency, low-power, and highly reliable edge implementation.
E-Skin-Integrated Robotic Hand Inspired by Human Tactile Perception and Cognition
- Project Manager
- TAKEI Kuniharu
- Professor, Graduate School of Information Science and Technology, Hokkaido University

Our project aims to realize and electronic skin (e-skin) that mimics tactile perception and cognitive functions of human fingertips, and to develop a robotic hand equipped with this e-skin. Unlike conventional rigid sensors, e-skin is a soft and flexible sensor sheet that can bend and deform like human skin. In this project, we will develop and integrate the e-skin based on previously developed by the PM (an example is shown in the lower right figure) with machine learning to reproduce the ambiguous and subjective aspects of human tactile perception, such as slip, roughness, softness, and tactile feel. Furthermore, by integrating this e-skin system into a robotic hand, we aim to realize a system that can learn and adapt, as humans do, while recognizing the state of the object being grasped. Through this research, we aim to establish fundamental technologies for a future society in which humans and robots can live together naturally, with humanoid robotics possessing human-line tactile perception and sensitivity and becoming part of the family.
Embodied Safety by Robotic Core Elements: Creating Intrinsically Safe Mechanisms by Extracting Principles from the Living Body’s Inherent Underactuated Drive Mechanisms
- Project Manager
- TADAKUMA Kenjiro
- Professor, Graduate School of Engineering Science, The University of Osaka

This research focuses on the hands and arms—the critical points of physical contact that enable AI-powered humanoid robots to work safely in people’s everyday living spaces. Our goal is to develop hands and arms that make grasping failures less likely to lead to serious accidents. Going beyond reliance on sensors and stop functions alone, we embed mechanisms inspired by the human body into the robot’s core physical structure. These include underactuation, which allows multiple joints to move with fewer actuators, and mechanical coupling that coordinates their motion. By building safety into the mechanism itself, we aim to create limbs that are less likely to exert dangerous forces, even when control systems malfunction or mistakes occur during learning.
An AI Robot with a High-Efficiency Body for Mobility in Public Spaces
- Project Manager
- NAKAGAWA Chihiro
- Professor, Graduate School of Engineering, Osaka Metropolitan University

This project aims to develop a humanoid body design with wheeled feet that can move stably across different speed ranges and use cases, from pedestrian areas such as sidewalks to roadside and delivery environments. In addition to energy-efficient wheeled locomotion, the robot will use the degrees of freedom of its upper body and legs for posture stabilization, establishing a technological foundation for safe and smooth mobility in public spaces shared with people. We will also evaluate the robot's behavior when passing or accompanying people and feed the results into design, control, and ELSI, with the aim of establishing a new locomotion principle that spans the "last mile" to the "last step."
Learning to Learn: Principles of Active On-Site Learning for General-Purpose Robots
- Project Manager
- NONAKA Tetsushi
- Professor, Graduate School of Human Development and Environment, Kobe University

Toward the realization of robots that continuously learn from the environment in which they are embedded, this project explores the principle of “learning to learn”: learning to obtain information relevant to the situation by spontaneously acting on the environment. We focus on tasks in which a robot uses tools on the spot to organize purposive encounters with the environment. Drawing on the approaches of reservoir computing and embodied intelligence, we aim to open a path toward robots that actively move their bodies to tune their attention to the information that specifies affordances—the possibilities for action offered by the human environment.
An Elemental Study of Motion Assist Robots Capable of Inferring Human States
- Project Manager
- YOSHIMURA Natsue
- Professor, School of Computing /Institute of Biomedical Engineering, Institute of Science Tokyo
This study aims to establish fundamental technologies for equipping robots with the ability to “infer” how to provide movement assistance without causing discomfort to the user. Humans have the ability to intuitively “infer” the movement speed and level of force that are comfortable for others. By estimating physiological changes associated with discomfort from biosignals, we hypothesize that humanoid robots can be equipped with the ability to “infer” natural and comfortable assistive movements. To achieve this goal, we will identify and validate physiologically grounded biomarkers of discomfort through multimodal biosignal measurements in humans and non-human primates, and develop practical technologies* for estimating natural assistive movements. (*patent pending)
Past Project (Click here)
Past Project
Smart Robot that is Close to One Person for a Lifetime
- Project Manager
- SUGANO Shigeki
- Professor, Faculty of Science and Engineering, Waseda University
This project aims to establish robot evolution technology that combines flexible machine hardware and unique AI that can understand many kinds of tasks. Our final goal is to build a human-robot symbiotic society by introducing a general-purpose AI robot that can work with people not only in housework and customer service but also in welfare and medical fields where human resources will be in short supply by 2050.
Collaborative AI robots for adaptation of diverse environments and innovation of infrastructure construction
- Project Manager
- NAGATANI Keiji
- Professor, Institute of Systems and Information Engineering, University of Tsukuba
This project aims to develop collaborative AI robots that respond to various situations flexibly and perform given tasks in challenging environments such as disaster sites. By 2050 these collaborative AI robots will, on behalf of humans, conduct emergency response missions following natural disasters. This technology will also be useful for the construction and maintenance of ground infrastructure.
Co-evolution of Human and AI-Robots to Expand Science Frontiers
- Project Manager
- HARADA Kanako
- Professor, Graduate School of Medicine, Graduate School of Engineering, The University of Tokyo
This project aims to develop AI-robots that conduct scientific experiments in challenging environments (e.g. in a hazardous atmosphere, or in a micro-scale setup), while interacting with scientists as their peers. AI robots and scientists will have freer interactions, and will work with unfamiliar objects and environments through trial-and-error together. By 2050 AI-robots will discover their own principles and solutions in the science fields.
Adaptable AI-enabled Robots to Create a Vibrant Society
- Project Manager
- HIRATA Yasuhisa
- Professor, Graduate School of Engineering, Tohoku University
This project aims to create a collective of adaptable AI-enabled robots available at a variety of places. Each robot will be usable by anyone at any time, and will adjust its form and functions according to the individual user to provide optimal assistance and services. By 2050 the co-existence and co-evolution of a wide variety of robots and people will create a vibrant society in which all people can participate.
New Life Spheres Opened up by AI Robots
- Project Manager
- UENO Munetaka
- Research and Engineering leader, Space Exploration Innovation Hub Center, Japan Aerospace Exploration Agency
The goal of international human exploration program is to establish independent biospheres in the extreme environments of the Moon and Mars, shaking off our dependency on Earth. This research project aims to realize biospheres in which humans can be active for a long period of time by conducting research and development toward the construction of a base system with smart technology, behavior-modifying technology, etc., while developing and utilizing AI robot technology for the elements backcasted by this achievement.
AI & Robots that Harmonize with Humans to Create Knowledge and Cross Its Borders
- Project Manager
- USHIKU Yoshitaka
- Vice President for Research, OMRON SINIC X Corporation
Deductive reasoning is necessary for paradigm-sustaining innovation. For paradigm disruption, abductive reasoning and knowledge creation have a key role. Transilience is also required for transdisciplinary paradigm disruption. This project aims to realize an AI that first understands and reviews such researchers' ideas based on their research articles. We will then develop AI robots that can conduct research in a loop of assertion, experiment, analysis, and description while interacting with human researchers by 2030. We aim for a world where humans and AI are in harmony and produce Nobel Prize-level research by 2050.
AI Robots which Help to Envision Promising Future Together with Users and Encourage Action toward It
- Project Manager
- OTAKE Mihoko
- Team Leader, RIKEN Center for Advanced Intelligence Project
Behavioral change support robots will be developed, which help identify personal values, and encourage actions leading to well-being based on the identified personal values. This project aims to develop three key technologies: 1) to collect diverse stories including wisdom, knowledge, and experiences; 2) to estimate feelings, thoughts, and personal values from verbal and nonverbal behaviors during conversations; 3) to encourage actions through providing stories which indicate novel perspectives and manners based on identified personal values. We aim to realize AI robots that will by 2050 help to envision promising future together with users and encourage users for actions towards them.
Intelligent Multi Agents for Exploration and Settlement in Unknown and Unexplored Areas
- Project Manager
- KUNII Yasuharu
- Professor, Faculty of Science and Engineering, Chuo University
Our project aims to explore and construct a habitable environment in the unknown environments of lunar lava tubes using small swarm robots. We tackle the research and development of both software and hardware aspects of the necessary functions for achieving our goals, including the ability for small exploration robots to gather in swarms and perform autonomous behaviors, functions for robots and systems to evolve, robot locomotion mechanisms to traverse challenging environments, and intelligence through shared AI functions. Through these efforts, we aim to create a future where humans can live inside lunar lava tubes by 2050.
Awareness AI Robot System for leading proactive behavior improvement
- Project Manager
- SHIMODA Shingo
- Designated Professor, Graduate School of Medicine, Nagoya University
This project aims to develop Awareness AI to support our proactive lives based on our individual requirements, social roles, and hopes for the future. In the modern society where values among the people is diverged, people must become aware of what to do or what they want to do by ourselves in daily life. Awareness AI assists this decision via the appropriate stimulation of our unconscious thought processes. By 2050, we create a society where everybody can live proactively according to their best-fit social role and hopes for the future through the awareness AI support.
New World of Inspiration by Co-evolution of Humans, AI Robots, and Biological Cyborgs
- Project Manager
- MORISHIMA Keisuke
- Professor, Graduate School of Engineering, Osaka University
By analyzing activity information and surrounding environment information obtained from a group of biological cyborgs equipped with ultra-small sensors, communication equipment and behavior control units, we will understand the principles of action and use them to develop a self-organizing platform using AI that stimulates human behavior and enables people and robots to collaborate without any sense of incongruity. By 2050, we aim to create a world where people and robots can work in harmony with each other.
Self-Evolving AI Robot System for Lunar Exploration and Human Outpost Construction
- Project Manager
- YOSHIDA Kazuya
- Professor, Graduate School of Engineering, Tohoku University
This project aims to develop a self-evolving AI robot system for lunar exploration and human outpost construction. Core technologies will be established that effectively utilize the components deployed to the moon, enabling modules to be reconfigured according to lunar conditions and mission tasks. By 2050, exploration and resource utilization on the moon will be promoted to realize sustainable outposts for human presence in space.
Program Overview through November 2025
(Click here)
Moonshot Goal 3Realization of AI robots that autonomously learn, adapt to their environment, evolve in intelligence and act alongside human beings, by 2050.
Program Director (PD)FUKUDA ToshioVisiting Professor, Institute of Innovation for Future Society, Nagoya University
Considering Japan’s declining birthrate and aging population, it is important that robots can be used in all aspects of society - such as working in dangerous or understaffed sites, developing human frontiers, and supporting our everyday lives. For that purpose, robots must be able to learn and act on their own through the co-evolution of AI and robots. Our R&D aims to realize AI robots with advanced bodies and self-developed AI learning.
A Vision of Society in 2050 (Illustrated Guide)
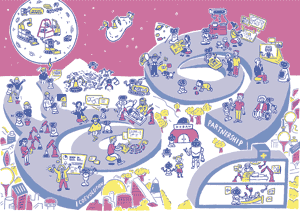
What might the future look like in 2050 if Goal 3 is realized? An illustrated guide.
Message from PD
Our R&D aims to achieve the following three outcomes by 2050:
(1) AI robots that autonomously make judgements and act in environments where it is difficult for humans to act.
(2) An automated AI robot system that aims to discover impactful scientific principles and solutions, by thinking and acting in the field of natural science.
(3) AI robots that humans feel comfortable with, have physical abilities equivalent to or greater than humans, and grow in harmony with human life.
The following two concepts are core to our work:
(1) Coevolution: AI technology and robot technology cooperate to improve their own performance.
(2) Self-organization: AI technology and robot technology self-modify their own knowledge and functions to adapt to their environment.

Advisors
Click here to see the list of advisors
| FUJITA Masahiro* | Representative of MF AI-Robotics Laboratory |
|---|---|
| KARASAWA Kaori | Professor Emeritus, The University of Tokyo / Senior Research Fellow, Graduate School of Engineering, The University of Tokyo |
| KONNO Atsushi | Professor, Faculty of Information Science and Technology, Hokkaido University |
| HARADA Tatsuya | Professor, Research Center for Advanced Science and Technology, The University of Tokyo |
| HOSODA Koh | Professor, Graduate School of Engineering, Kyoto University |
| MURAKAMI Hiroki | Technical Advisor, Corporate Research & Development Division, IHI Corporation |
| YOKOI Kazuhito | Director General, Technology and Innovation Strategy Center, NEDO |
*Sub Program Director
Goal 3 News
Contact
Goal 3 Secretariat
Department of Moonshot Research and Development Program, Japan Science and Technology Agency
e-mail moonshot-goal3 jst.go.jp